AI Control System for an Autonomous Car
Sampled PID control with disturbance and noise models
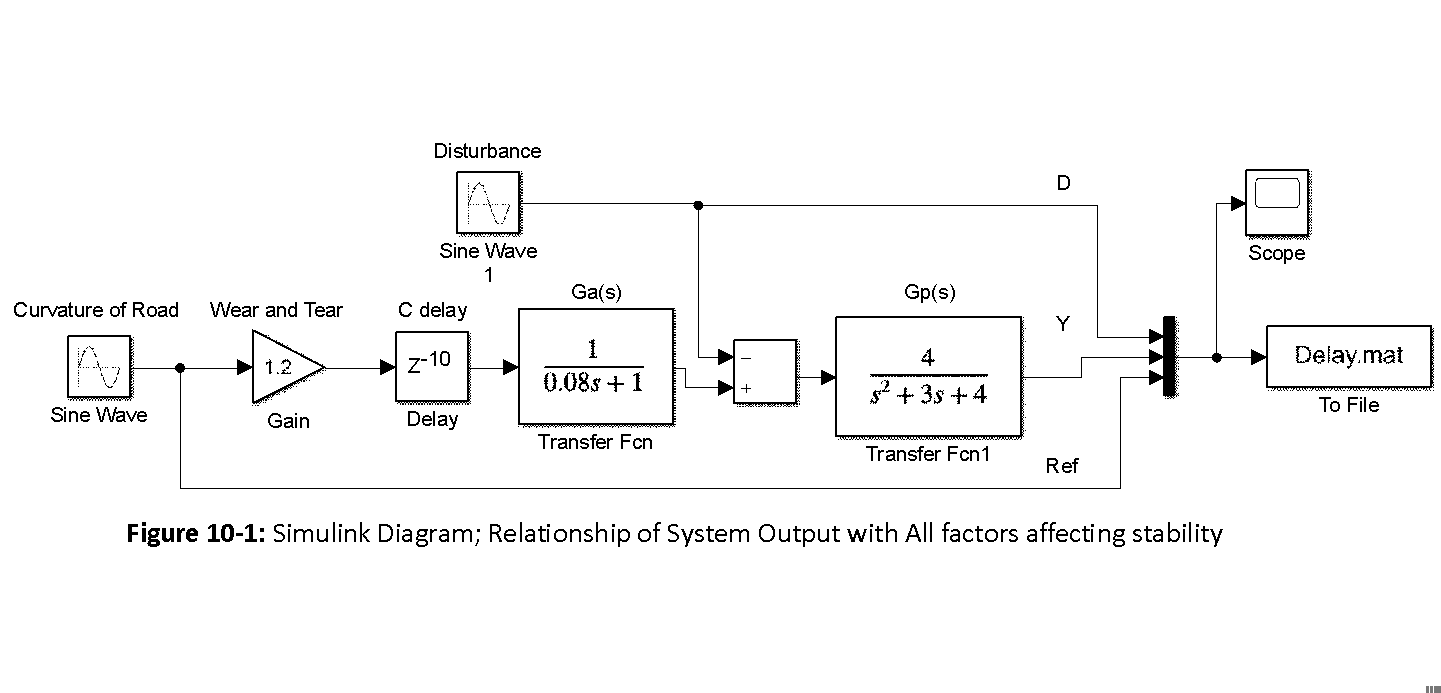
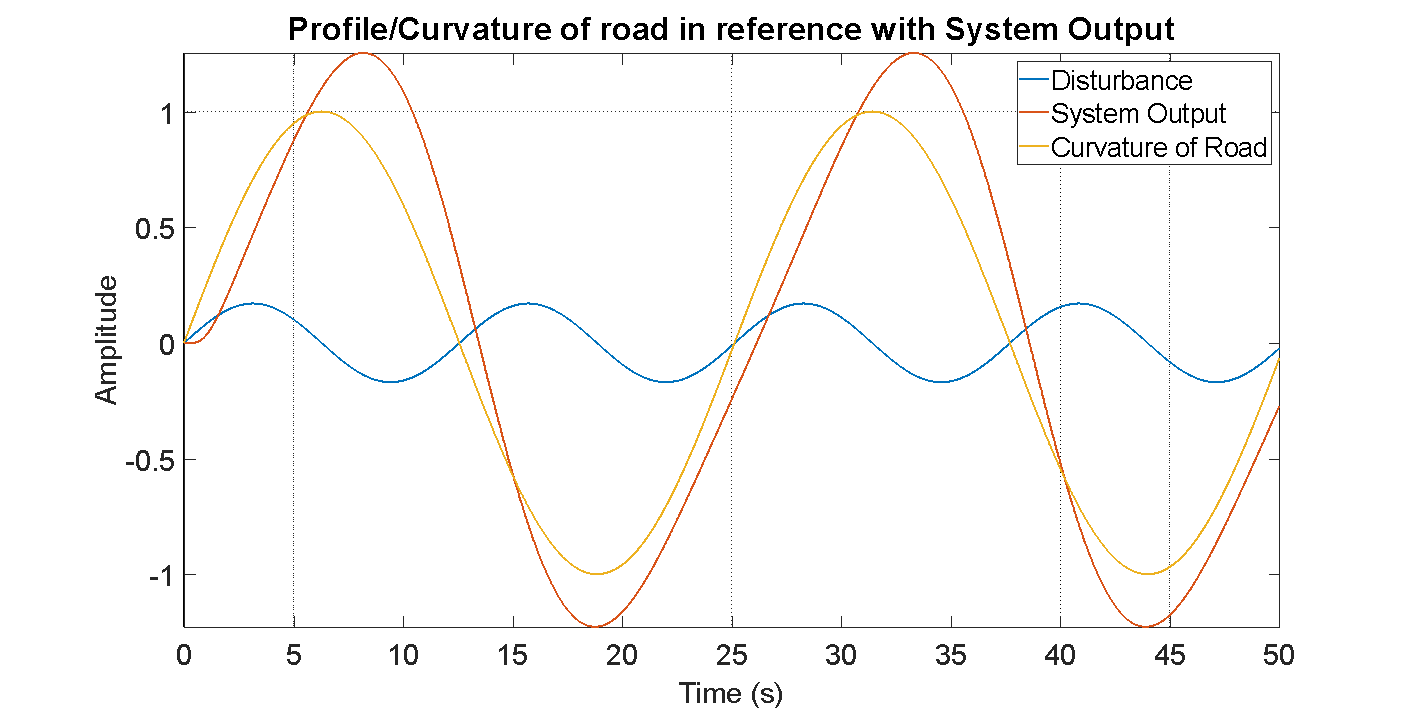
Designed open-loop then closed-loop Simulink / MATLAB control systems for an autonomous-car simulation. Applied the Shannon–Nyquist theorem, modelled road curvature, wear, computational delay, and measurement noise, and settled on a sampled PID controller.
The Core Challenge
Engineering Solution & Implementation
Started with an open-loop Simulink model and MATLAB assist code, then closed the loop. Compared digital vs analogue control, added disturbance channels (road curvature, wear, delay), and established a sampled PID controller. Supervisor: Dr James E. Pickering.
Verified Outcomes & Deliverables
Closed-loop sampled PID that corrects the car on the road simulation.
Modelled measurement noise and ±10% coefficient faults.
Documented Shannon–Nyquist sampling against total simulation time.